
Pneumatic computer memory helps robot control its movements
Engineers at the University of California, Riverside, unveiled pneumatic computer memory in the summer of 2021 that can be used to control soft robots. The innovation overcomes one of the biggest obstacles to the development of soft robotics: the fundamental mismatch between pneumatics and electronics. The researchers published their work in PLOS One.
The scientific paper states: "Pneumatic soft robots have advantages over traditional rigid robots in many applications. In particular, their flexible bodies and soft, air-driven movements make them better suited for use near people and other objects that could be injured or damaged by traditional robots. However, existing systems for controlling soft robots currently require specialized electromechanical equipment (typically solenoid valves) to maintain the actuation state (extended or compressed) of each independent actuator."
Pneumatic soft robots use compressed air to move soft, flexible limbs and grippers. They are much better than traditional rigid robots at performing delicate tasks. Such robots are also safer for people.
However, existing control systems for soft pneumatic robots still use electronic valves and computers to maintain the position of the robot's moving parts. These electronic components significantly increase the cost, size and power consumption of soft robots, which limits their capabilities.
To move soft robotics into the future, a team led by Dr. Shane Hoang, Professor of Bioengineering William Glover, Professor of Computer Science Philip Brisk and Professor of Mechanical Engineering Konstantinos Karydis turned to the past.
"Pneumatic logic" preceded electronic computers and once provided advanced control in a wide range of products, from thermostats and other climate control components to pianos in the early 1900s. In pneumatic logic, air rather than electricity passes through circuits or channels, and air pressure is used to denote on/off or true/false. In modern computers, these logic states are represented by the codes 1 and 0 to start or stop electrical charges.
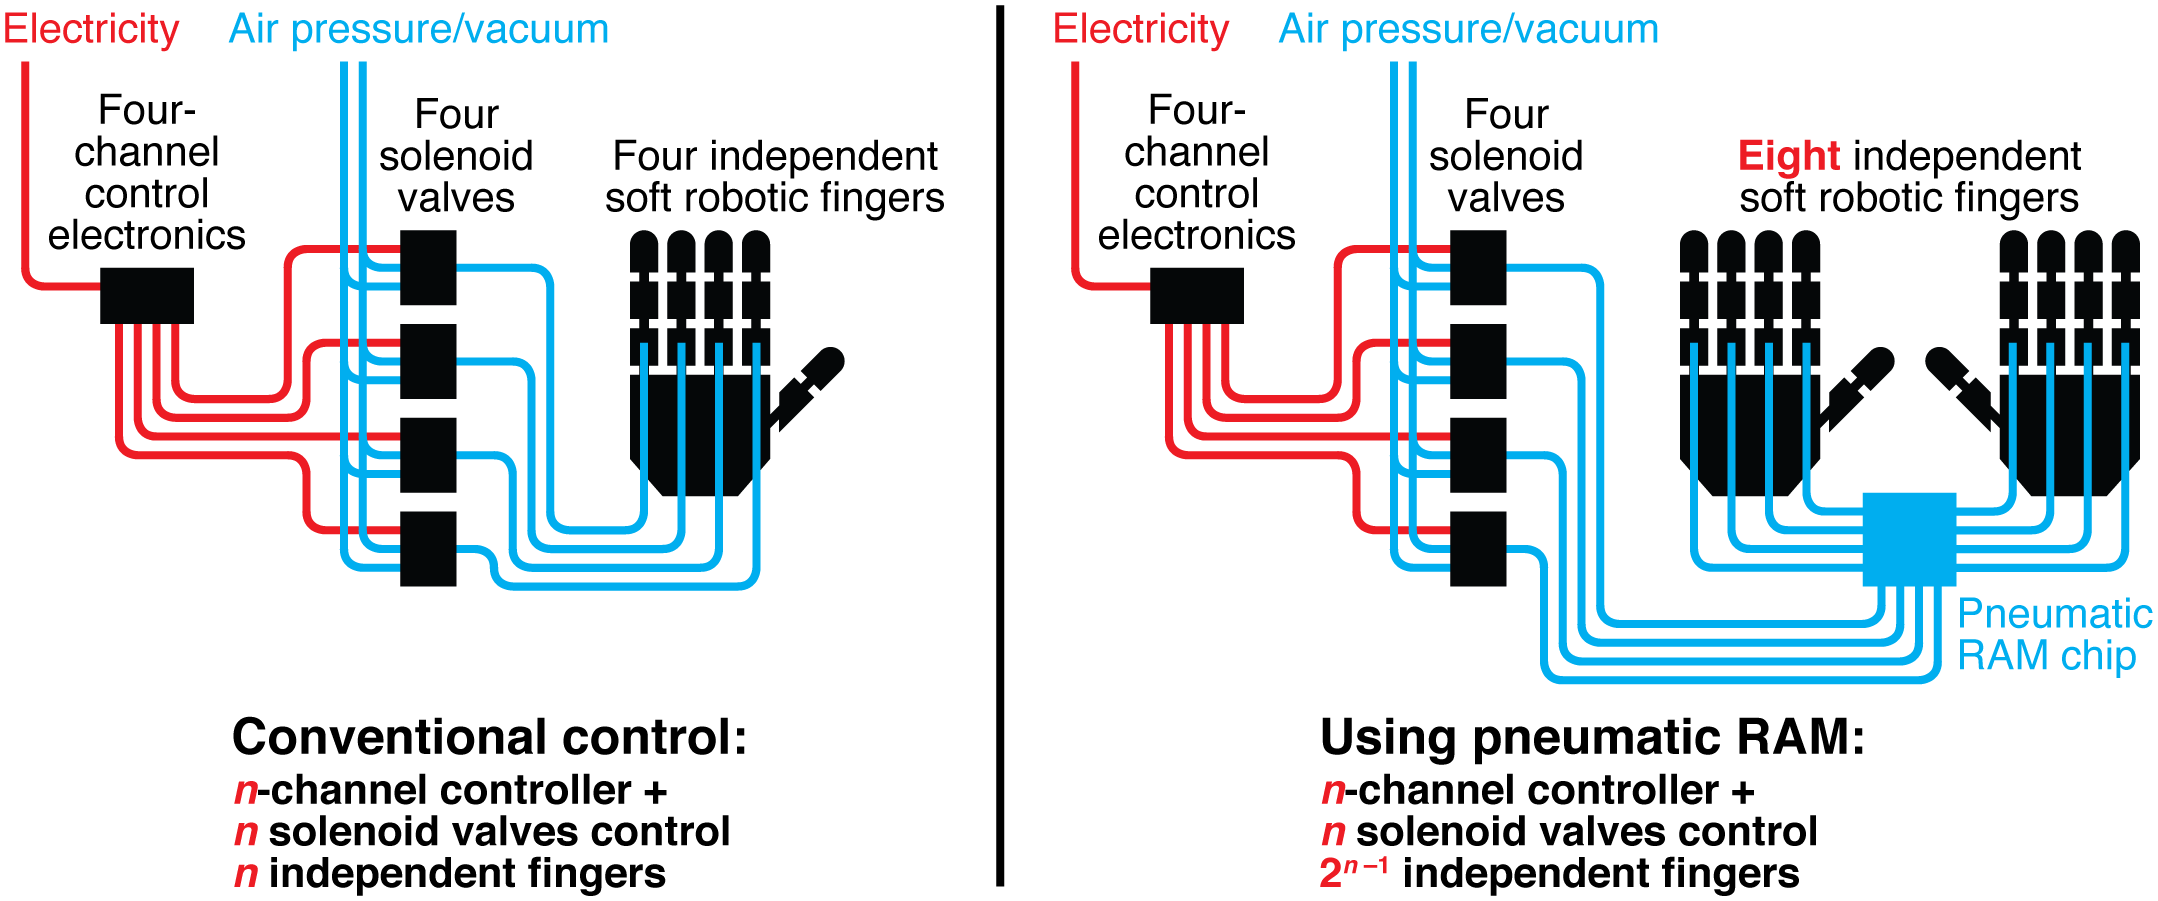
Pneumatic soft robots need a way to remember and maintain the position of their moving parts. The researchers realized that if they could create pneumatic logic "memory" for a soft robot, they could eliminate the electronic memory currently used for this purpose.
The researchers built their pneumatic random access memory (RAM) chip using microfluidic valves instead of electronic transistors. Microfluidic valves were originally designed to control the flow of liquid on relevant chips, but they can also control the flow of air.
The valves stay closed due to pressure differences even when disconnected from the air supply, creating delayed pressure differences that function as memory and maintain the states of the robot's actuators. Dense arrays of these valves can perform complex operations and reduce the use of expensive, bulky and energy-intensive electronic equipment typically used to control pneumatic robots.
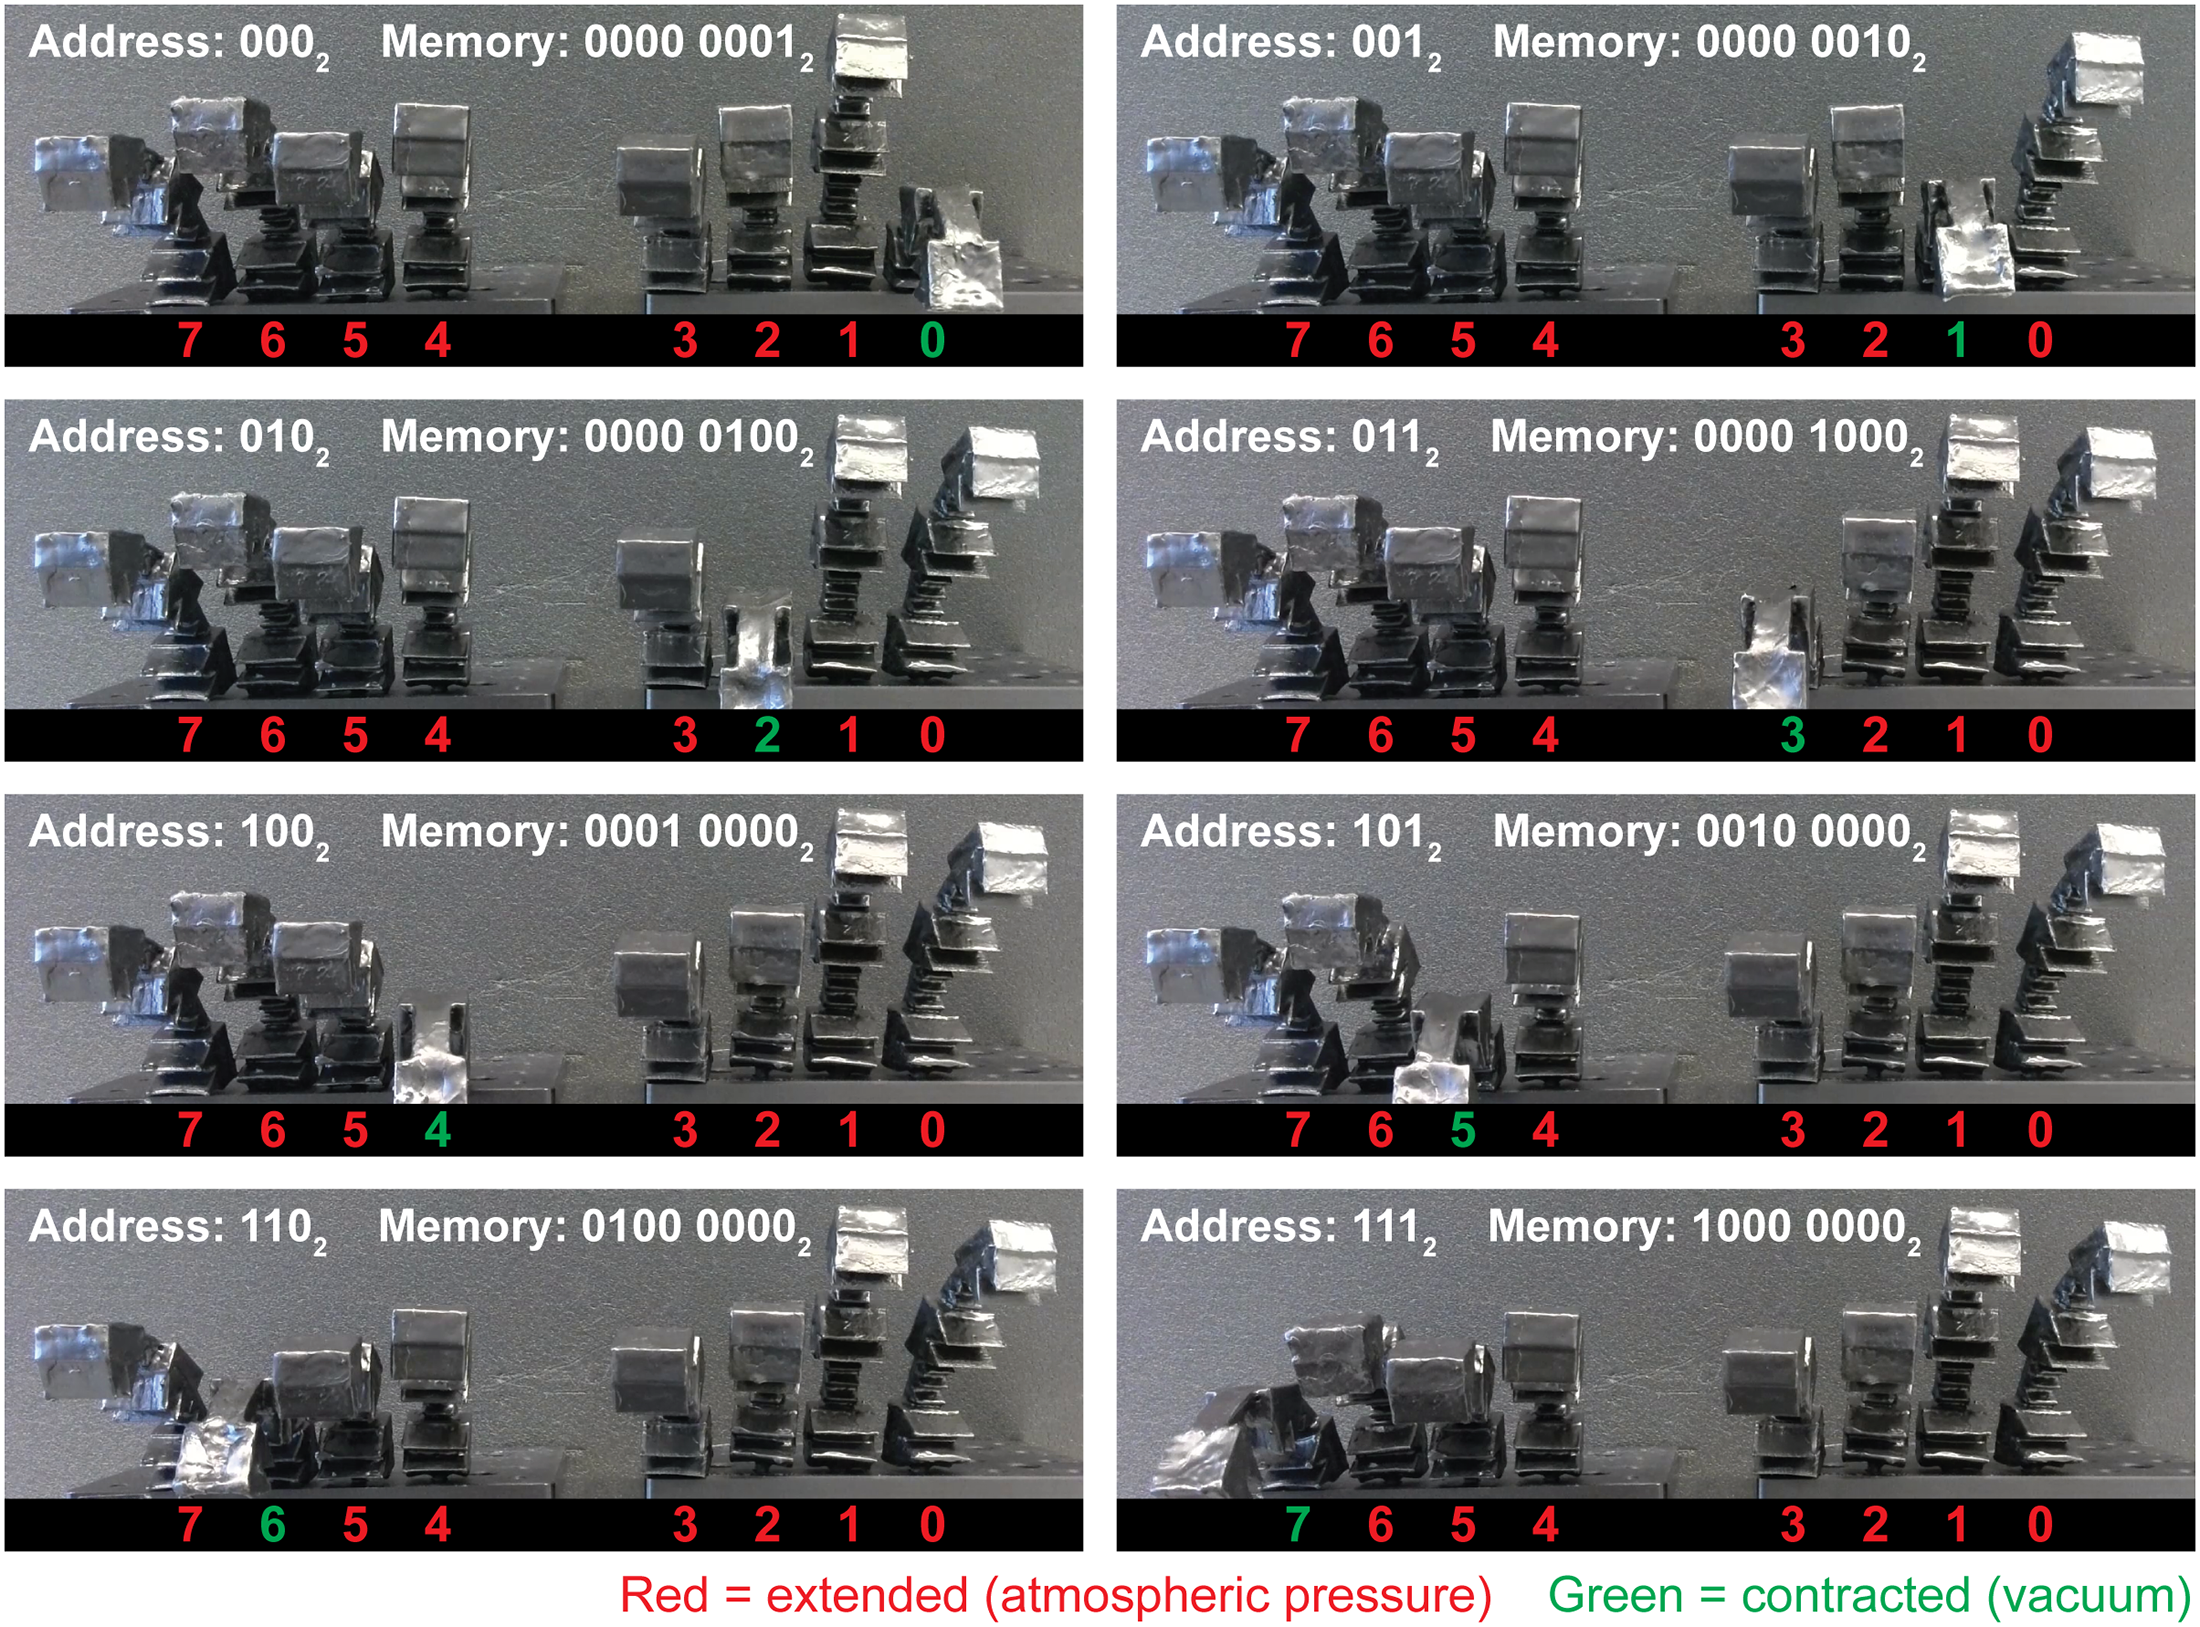
After modifying the microfluidic valves to handle large air flows, the team created an 8-bit pneumatic RAM (random access memory) chip capable of controlling larger and faster-moving soft robots, and integrated it into a pair of rubber hands printed on a 3D printer. Pneumatic RAM uses atmospheric air pressure to represent the value "0" or "false" and vacuum to represent the value "1" or "true". The robot's soft fingers extend at atmospheric pressure and contract when connected to a vacuum.
By varying combinations of atmospheric pressure and vacuum in the channels on the RAM chip, the researchers were able to make the robot play notes, chords and even the entire song "Mary Had a Little Lamb" on a piano.
In theory, this system could be used to control other robots without any electronic equipment, using only a battery-powered pump to create a vacuum. The researchers note that without positive pressure anywhere in the system, only at normal atmospheric air pressure, there is no risk of accidental pressure spikes and serious failure of the robot or its control system.
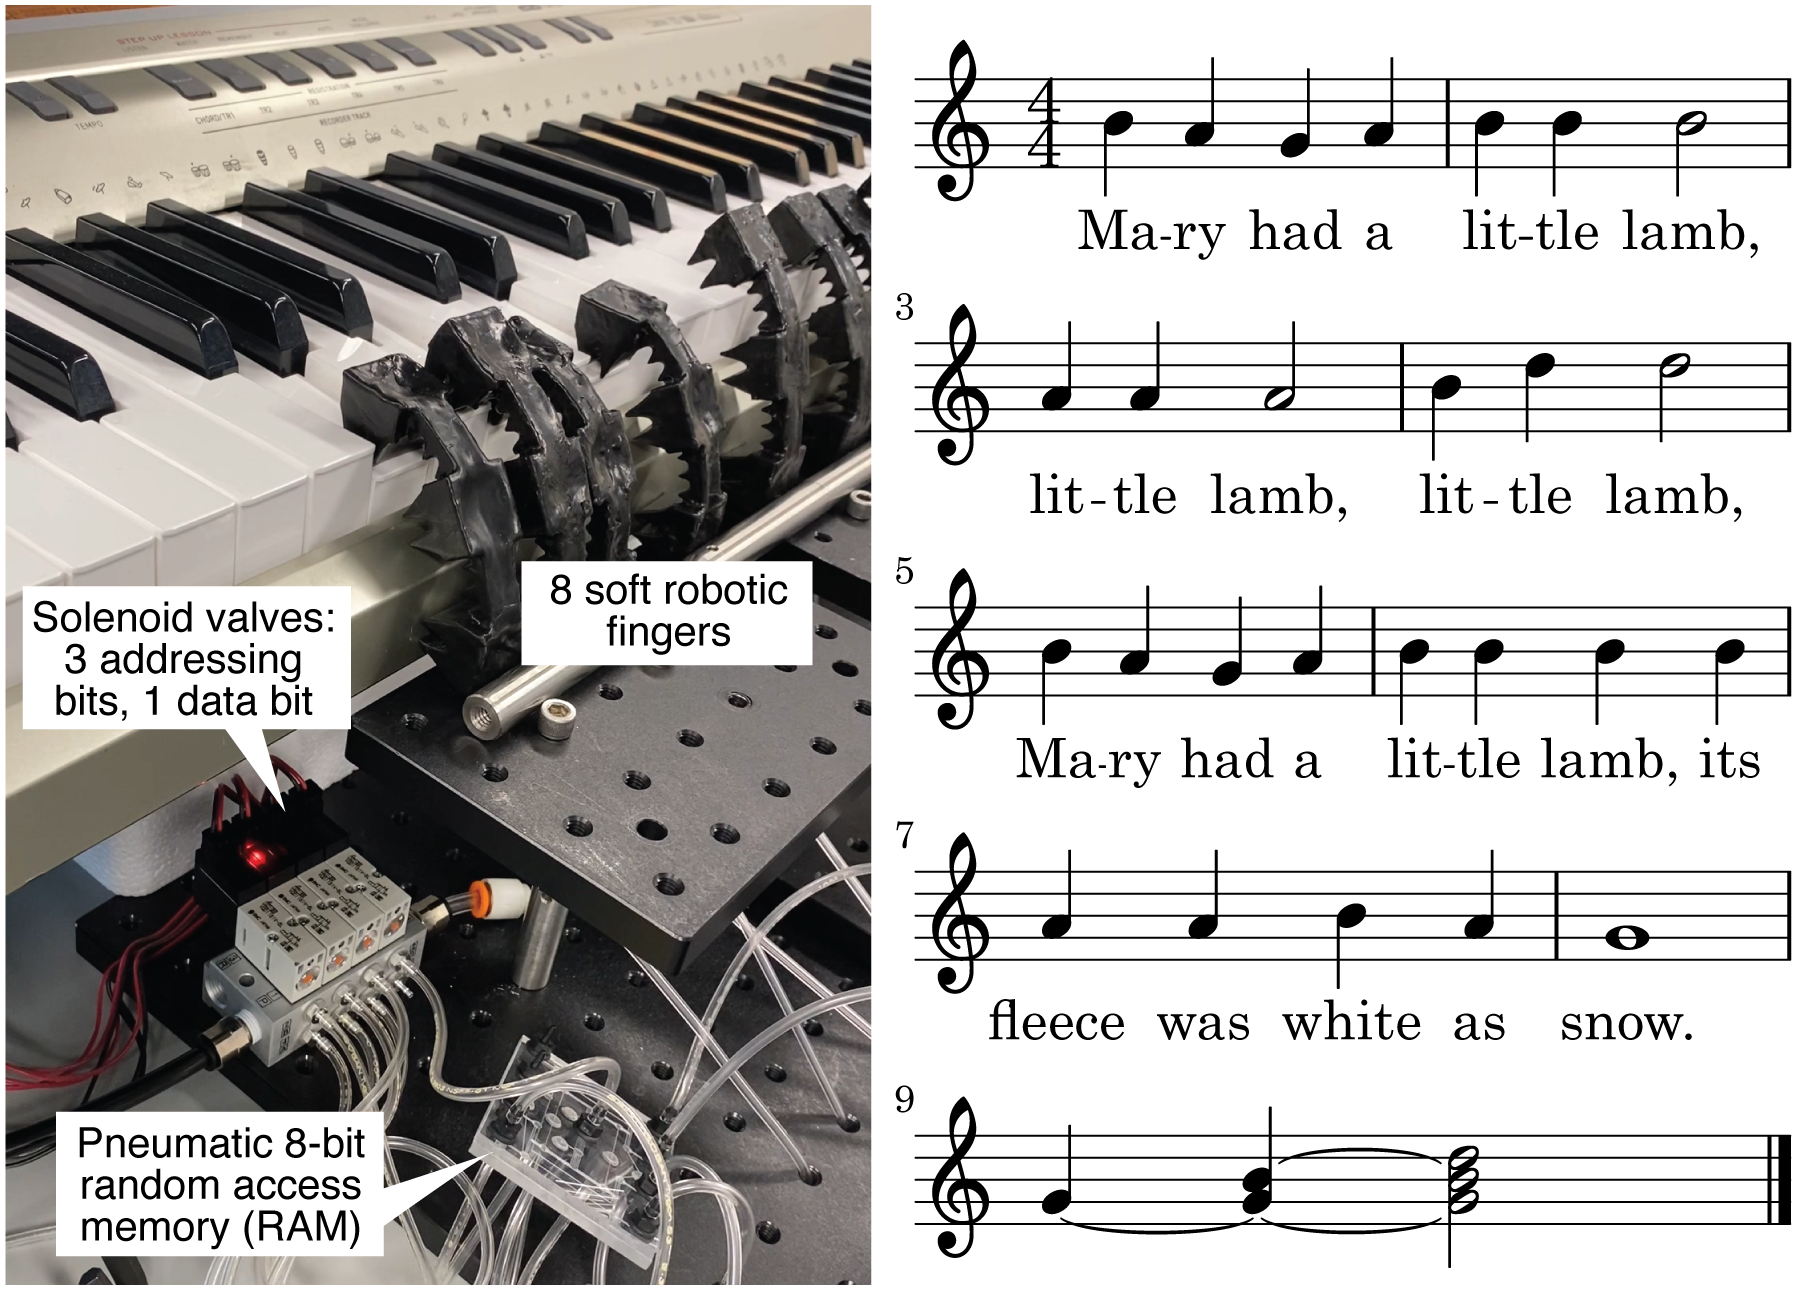
Robots using this technology will be especially safe for delicate use on or near people, for example in wearable devices for infants with motor impairments.
Of course, this technology is far from everyday use. In addition to necessary improvements in complexity and speed, robots will need software versions of processors and other components to completely eliminate the need for rigid electronics. However, the goal is clear. Pneumatic memory could at least reduce the need for microchips in soft robots and points to the future of fully flexible robotics that won't harm you in a collision.


