
MIT Control System Improves Agility of Mini Cheetah Quadruped Robot
A fast cheetah races across a hilly field, leaping over sudden gaps in the rough terrain. The movement may look effortless from the outside, but getting a robot to move this way is a completely different challenge.
In recent years, quadruped robots inspired by the movements of cheetahs and other animals have made big strides forward, but they still lag behind their mammalian counterparts when it comes to traveling over landscapes with rapidly changing elevation.
“In such conditions, you need to use vision to avoid failures. For example, it is hard to avoid stepping into a gap if you cannot see it. Although some methods exist for incorporating vision into legged locomotion, most of them are actually not suitable for use with evolving flexible robotic systems”
Margolis and his colleagues at the MIT Artificial Intelligence Laboratory developed a system that improves the speed and agility of legged robots when they jump across gaps in the terrain. The new control system is divided into two parts: one processes real-time input from a video camera mounted on the front of the robot, and the other converts this information into instructions about how the robot should move its body.
The researchers tested their system on the Mini Cheetah, a powerful and agile robot built in the laboratory of mechanical engineering professor Sangbae Kim. Unlike other control methods for quadruped robots, this two-part system does not require prior mapping of the terrain, so the robot can go anywhere. In the future, this could allow robots to head into forests on emergency response missions or climb stairs to deliver medicine to elderly people.
Everything under control
Using two separate controllers working together makes this system particularly innovative. A controller is an algorithm that converts the robot's state into a set of actions it must follow. Many blind controllers, meaning those without vision, are reliable and efficient, but they only allow robots to move across continuous terrain.
Vision is such a complex sensory input to process that these algorithms cannot handle it efficiently. Systems that include vision typically rely on a "height map" of the terrain, which must either be built in advance or generated on the fly, a process that is usually slow and prone to failure if the height map is inaccurate.
To develop their system, the researchers took the best elements from these reliable blind controllers and combined them with a separate module that processes vision in real time. The robot's camera captures depth images of the approaching terrain, which are passed to a high-level controller along with information about the robot's body state (joint angles, body orientation). The high-level controller is a neural network that "learns" from its own experience.
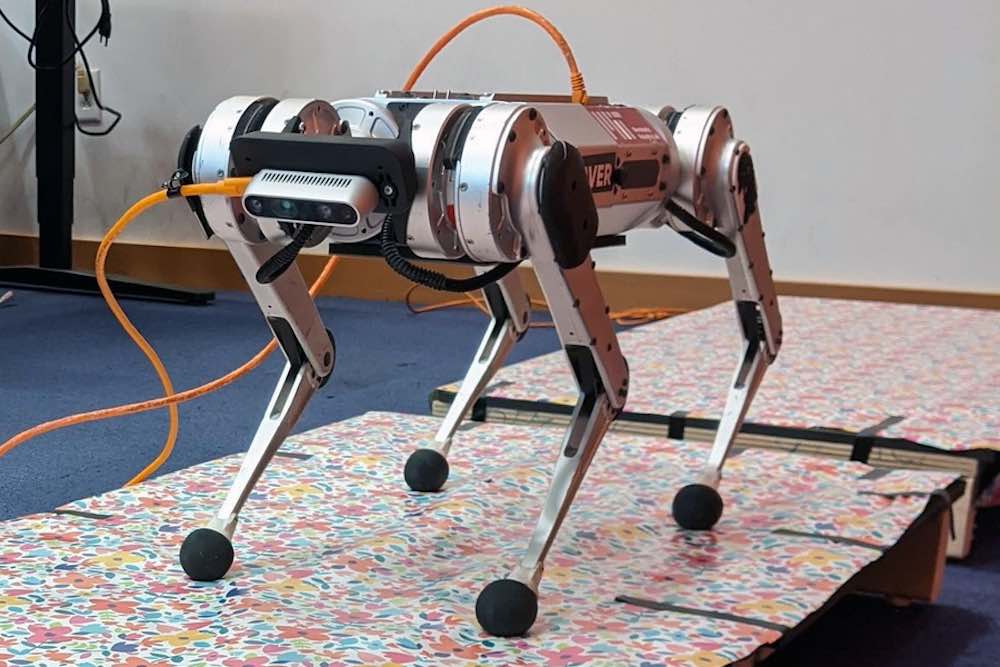
This neural network outputs a target trajectory, which the second controller uses to determine the torque for each of the robot's 12 joints. The low-level controller is not a neural network; instead, it relies on a set of concise physical equations describing the robot's motion.
“The hierarchy, including the use of this low-level controller, allows us to constrain the robot's behavior so that it acts more correctly. In the low-level controller, we use well-defined models on which we can impose constraints, which is usually impossible in a network based on learning”
Training the network
The researchers used a trial-and-error method known as reinforcement learning to train the high-level controller. They simulated the robot running across hundreds of different intermittent landscapes and rewarded it for successful crossings. Over time, the algorithm learned which actions increase the reward.
They then built a physical terrain with gaps from a set of wooden boards and tested their control scheme with the Mini Cheetah.
“It was definitely fun working with a robot that was developed at MIT by some of our colleagues. The Mini Cheetah is a great platform because it is modular and made mostly of parts you can order online, so if we wanted a new battery or camera, it was a simple matter of ordering it from a regular supplier and installing it with a little help from Sangbae's lab”

In some cases, estimating the robot's state proved to be a challenge. Unlike simulation, real-world sensors face noise, which can accumulate and affect the outcome. So, for some experiments involving high-precision foot placement, the researchers used a motion capture system to measure the bot's true position.
Their system outperformed other systems that use only one controller, and the Mini Cheetah successfully traversed 90% of the terrain.
“One novelty of our system is that it responds to the robot's gait. If a person were trying to jump across a really wide gap, they might start with a very fast run to build up speed, then bring both feet together to make a really powerful leap across the gap. In the same way, our robot can adjust the timing and duration of foot contacts to better traverse the terrain”
Leaving the lab
According to the professor, although the researchers were able to demonstrate that their control scheme works in the lab, they still have a long way to go before they can deploy the system in the real world.
In the future, they hope to install a more powerful computer on the robot so it can perform all of its calculations on board. They also want to improve the robot's state estimator to eliminate the need for a motion capture system. In addition, the researchers plan to improve the low-level controller so it can use the robot's full range of motion, and the high-level controller so it works well under different lighting conditions.
“It is remarkable to witness the flexibility of machine learning methods that can bypass the carefully engineered intermediate processes (such as state estimation and trajectory planning) that model-based multi-stage methods relied on. I am excited about the future of mobile robots with more robust vision processing, trained specifically for locomotion”


